Overview
Refer to http://trenz.org/teb0912-info for the current online version of this manual and other available documentation.
Key Features
- Vitis/Vivado 2024.2
- PetaLinux
- SD
- 2x ETH
- MAC from EEPROM
- I2C
- PCIe (M2 and wifi)
- RTC (ISL12020)
- CAN
- FMeter
- PCIe
- LED
- Modified FSBL for SI5395 programming (Vitis Classic and Petalinux patch)
Revision History
Release Notes and Know Issues
| Issues | Description | Workaround | To be fixed version |
|---|---|---|---|
| No known issues | --- | --- | --- |
Known Issues
Requirements
Software
| Software | Version | Note |
|---|---|---|
| Vitis | 2024.2 | needed, Vivado is included into Vitis installation |
| PetaLinux | 2024.2 | needed |
| SI ClockBuilder Pro | --- | optional |
Software
Hardware
Basic description of TE Board Part Files is available on TE Board Part Files.
Complete List is available on "<project folder>\board_files\*_board_files.csv"
Design supports following modules:
Design supports following carriers:
| Carrier Model | Notes |
|---|---|
| --- |
*used as reference
Hardware Carrier
Additional HW Requirements:
| Additional Hardware | Notes |
|---|---|
| SD Card | with FAT32 partition for booting |
| 2x ETH cable | optional for ethernet connection |
| Micro USB cable | for JTAG/UART |
| Power cable | with Molex Mini-Fit Female Crimp Terminal 5556 (0039000074) and Molex housing (0039012045) |
| Power supply unit | 12V 2A recommended |
*used as reference
Additional Hardware
Content
For general structure and usage of the reference design, see Project Delivery - Xilinx devices
Design Sources
| Type | Location | Notes |
|---|---|---|
| Vivado | <project folder>\block_design <project folder>\constraints <project folder>\ip_lib <project folder>\board_files | Vivado Project will be generated by TE Scripts |
| Vitis | <project folder>\sw_lib | Additional Software Template for Vitis and apps_list.csv with settings automatically for Vitis app generation |
| PetaLinux | <project folder>\os\petalinux | PetaLinux template with current configuration |
Design sources
Additional Sources
| Type | Location | Notes |
|---|---|---|
| SI5395 | <project folder>\misc\PLL\Si5395 | SI5395 Project with current PLL Configuration |
| init.sh | <project folder>\misc\sd\ | Additional Initialization Script for Linux to read temperature of six temperature sensors on the board. For more information refer to TEB0912 CPLD. |
Additional design sources
Prebuilt
File | File-Extension | Description |
|---|---|---|
| BIF-File | *.bif | File with description to generate Bin-File |
| BIN-File | *.bin | Flash Configuration File with Boot-Image (Zynq-FPGAs) |
| BIT-File | *.bit | FPGA (PL Part) Configuration File |
| Boot Script-File | *.scr | Distro Boot Script file |
| DebugProbes-File | *.ltx | Definition File for Vivado/Vivado Labtools Debugging Interface |
| Diverse Reports | --- | Report files in different formats |
| Device Tree | *.dts | Device tree (2 possible, one for u-boot and one for linux) |
| Hardware-Platform-Description-File | *.xsa | Exported Vivado hardware description file for Vitis and PetaLinux |
| LabTools Project-File | *.lpr | Vivado Labtools Project File |
| OS-Image | *.ub | Image with Linux Kernel (On Petalinux optional with Devicetree and RAM-Disk) |
| Software-Application-File | *.elf | Software Application for Zynq or MicroBlaze Processor Systems |
Prebuilt files (only on ZIP with prebult content)
Download
Reference Design is only usable with the specified Vivado/Vitis/PetaLinux version. Do never use different Versions of Xilinx Software for the same Project.
Reference Design is available on:
Design Flow
Reference Design is available with and without prebuilt files. It's recommended to use TE prebuilt files for first launch.
Trenz Electronic provides a tcl based built environment based on Xilinx Design Flow.
See also:
- Xilinx Development Tools#XilinxSoftware-BasicUserGuides
- Vivado Projects - TE Reference Design
- Project Delivery.
The Trenz Electronic FPGA Reference Designs are TCL-script based project. Command files for execution will be generated with "_create_win_setup.cmd" on Windows OS and "_create_linux_setup.sh" on Linux OS.
TE Scripts are only needed to generate the vivado project, all other additional steps are optional and can also executed by Xilinx Vivado/Vitis GUI. For currently Scripts limitations on Win and Linux OS see: Project Delivery Currently limitations of functionality
Caution! Win OS has a 260 character limit for path lengths which can affect the Vivado tools. To avoid this issue, use Virtual Drive or the shortest possible names and directory locations for the reference design (for example "x:\<project folder>")
Run _create_win_setup.cmd/_create_linux_setup.sh and follow instructions on shell:
_create_win_setup.cmd/_create_linux_setup.sh------------------------Set design paths---------------------------- -- Run Design with: _create_win_setup -- Use Design Path: <absolute project path> -------------------------------------------------------------------- -------------------------TE Reference Design--------------------------- -------------------------------------------------------------------- -- (0) Module selection guide, project creation...prebuilt export... -- (1) Create minimum setup of CMD-Files and exit Batch -- (2) Create maximum setup of CMD-Files and exit Batch -- (3) (internal only) Dev -- (4) (internal only) Prod -- (c) Go to CMD-File Generation (Manual setup) -- (d) Go to Documentation (Web Documentation) -- (g) Install Board Files from Xilinx Board Store (beta) -- (a) Start design with unsupported Vivado Version (beta) -- (x) Exit Batch (nothing is done!) ---- Select (ex.:'0' for module selection guide):
- Press 0 and enter to start "Module Selection Guide"
- Create project and follow instructions of the product selection guide, settings file will be configured automatically during this process.
optional for manual changes: Select correct device and Xilinx install path on "design_basic_settings.cmd" and create Vivado project with "vivado_create_project_guimode.cmd"
Note: Select correct one, see also Vivado Board Part Flow
Create hardware description file (.xsa file) for PetaLinux project and export to prebuilt folder
run on Vivado TCL (Script generates design and export files into "<project folder>\prebuilt\hardware\<short name>")TE::hw_build_design -export_prebuilt
Using Vivado GUI is the same, except file export to prebuilt folder.
- Create and configure your PetaLinux project with exported .xsa-file, see PetaLinux KICKstart
- use TE Template from "<project folder>\os\petalinux"
use exported .xsa file from "<project folder>\prebuilt\hardware\<short name>" . Note: HW Export from Vivado GUI creates another path as default workspace.
The build images are located in the "<plnx-proj-root>/images/linux" directory
(Optional) Configure the boot.scr file as needed, see Distro Boot with Boot.scr
- Generate Programming Files with Vitis (recommended)
- Copy PetaLinux build image files to prebuilt folder
copy u-boot.elf, system.dtb, bl31.elf, image.ub and boot.scr from "<plnx-proj-root>/images/linux" to prebuilt folder
"<project folder>\prebuilt\os\petalinux\<ddr size>" or "<project folder>\prebuilt\os\petalinux\<short name>"
- Generate Programming Files with Vitisrun on Vivado TCL (Script generates applications and bootable files, which are defined in "test_board\sw_lib\apps_list.csv")
TE::sw_run_vitis -all
TE::sw_run_vitis (optional; Start Vitis from Vivado GUI or start with TE Scripts on Vivado TCL)
TCL scripts generate also platform project, this must be done manually in case GUI is used. See Vitis
- Copy PetaLinux build image files to prebuilt folder
- Generate Programming Files with Petalinux (alternative), see PetaLinux KICKstart
Launch
Programming
Check Module and Carrier TRMs for proper HW configuration before you try any design.
Reference Design is also available with prebuilt files. It's recommended to use TE prebuilt files for first launch.
Get prebuilt boot binaries
- Run _create_win_setup.cmd/_create_linux_setup.sh and follow instructions on shell
- Press 0 and enter to start "Module Selection Guide"
- Select assembly version
- Validate selection
Select create and open delivery binary folder
Note: Folder "<project folder>\_binaries_<Article Name>" with subfolder "boot_<app name>" for different applications will be generated
QSPI-Boot mode
Option for Boot.bin on QSPI Flash and image.ub and boot.scr on SD or USB.
- Connect JTAG and power on carrier with module
Open Vivado Project with "vivado_open_existing_project_guimode.cmd" or if not created, create with "vivado_create_project_guimode.cmd"
run on Vivado TCL (Script programs BOOT.bin on QSPI flash)TE::pr_program_flash -swapp u-boot TE::pr_program_flash -swapp hello_trenz (optional)
- Copy image.ub and boot.scr on SD or USB
- use files from "<project folder>\_binaries_<Article Name>\boot_linux" from generated binary folder,see: Get prebuilt boot binaries
- or use prebuilt file location, see "<project folder>\prebuilt\file_location.txt"
- Set Boot Mode to QSPI-Boot and insert SD or USB.
- Depends on Carrier, see carrier TRM.
SD-Boot mode
- Copy image.ub, boot.src and Boot.bin on SD
- use files from "<project folder>\_binaries_<Article Name>\boot_linux" from generated binary folder, see: Get prebuilt boot binaries
- or use prebuilt file location, see "<project folder>\prebuilt\file_location.txt"
- Set Boot Mode to SD-Boot.
- Depends on Carrier, see carrier TRM.
- Insert SD-Card in SD-Slot.
JTAG
Not used on this example.
Usage
- Prepare HW like described on section Programming
- Connect UART USB (most cases same as JTAG)
Select SD Card as Boot Mode (or QSPI - depending on step 1)
Note: See TRM of the Carrier, which is used.
Starting with Petalinux version 2020.1, the industry standard "Distro-Boot" boot flow for U-Boot was introduced, which significantly expands the possibilities of the boot process and has the primary goal of making booting much more standardised and predictable.
The boot options described above describe the common boot processes for this hardware; other boot options are possible.
For more information see Distro Boot with Boot.scr- (Optional) Insert PCIe Card (detection depends on Linux driver. Only some basic drivers are installed)
- (Optional) Connect Network Cable
Power On PCB
Linux
- Open Serial Console (e.g. putty)
- Speed: 115200
select COM Port
Win OS, see device manager, Linux OS see dmesg |grep tty (UART is *USB1)
Linux Console:
# password disabled
petalinux login: root
Password: root
Note: Wait until Linux boot finished
You can use Linux shell now.
i2cdetect -y -r 0	(check I2C 1 Bus)
dmesg | grep rtc	(RTC check)
udhcpc				(ETH0/1 check)
lspci				(PCIe check)
Option Features
- Webserver to get access to ZynqMP
- insert IP on web browser to start web interface
- init.sh scripts
- add init.sh script on SD, content will be load automatically on startup (template included in "<project folder>\misc\SD")
- This Script file is responsible to read temperature of six temperature sensors on the board. For more information refer to TEB0912 CPLD.
- add init.sh script on SD, content will be load automatically on startup (template included in "<project folder>\misc\SD")
- Webserver to get access to ZynqMP
Vivado HW Manager
Open Vivado HW-Manager and add VIO signal to dashboard (*.ltx located on prebuilt folder)
- Control:
- User LED Control (D16, D15)
- Monitoring:
- MGT CLK Measurement:
- Open Vivado HW-Manager and add VIO signal to dashboard (*.ltx located on prebuilt folder). Set radix from VIO signals to unsigned integer.Note: Frequency Counter is inaccurate and displayed unit is Hz
- Default
- B128_CLK_P, B131_CLK_P: 125MHz
- B129_CL_P, B130_CLK_P: 312,5MHz
- B224_CLK1 - B231_CLK1: 125MHz
- B65_HP_CLK_P: 200MHz
- MGT CLK Measurement:
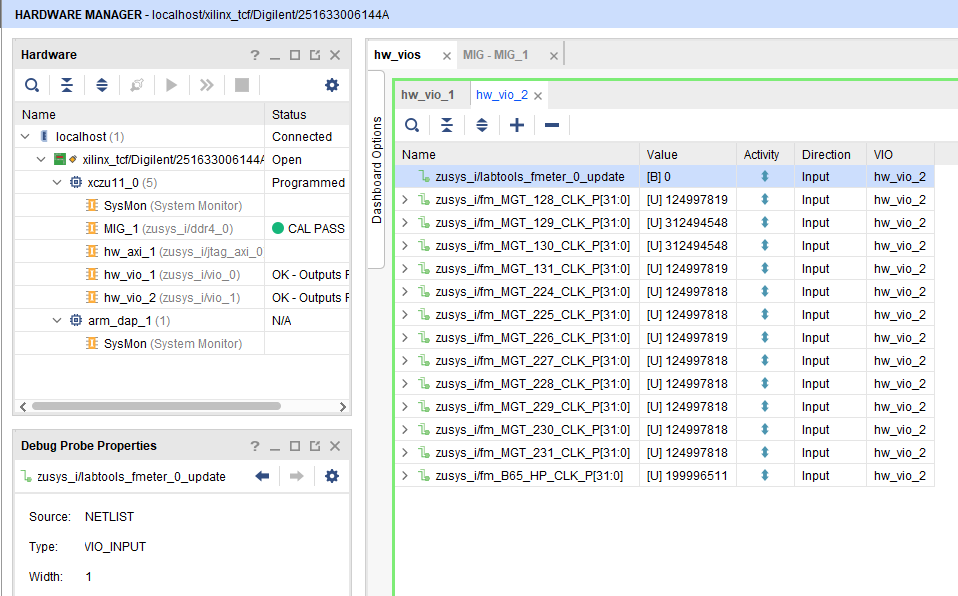
Vivado Hardware Manager
System Design - Vivado
Block Design
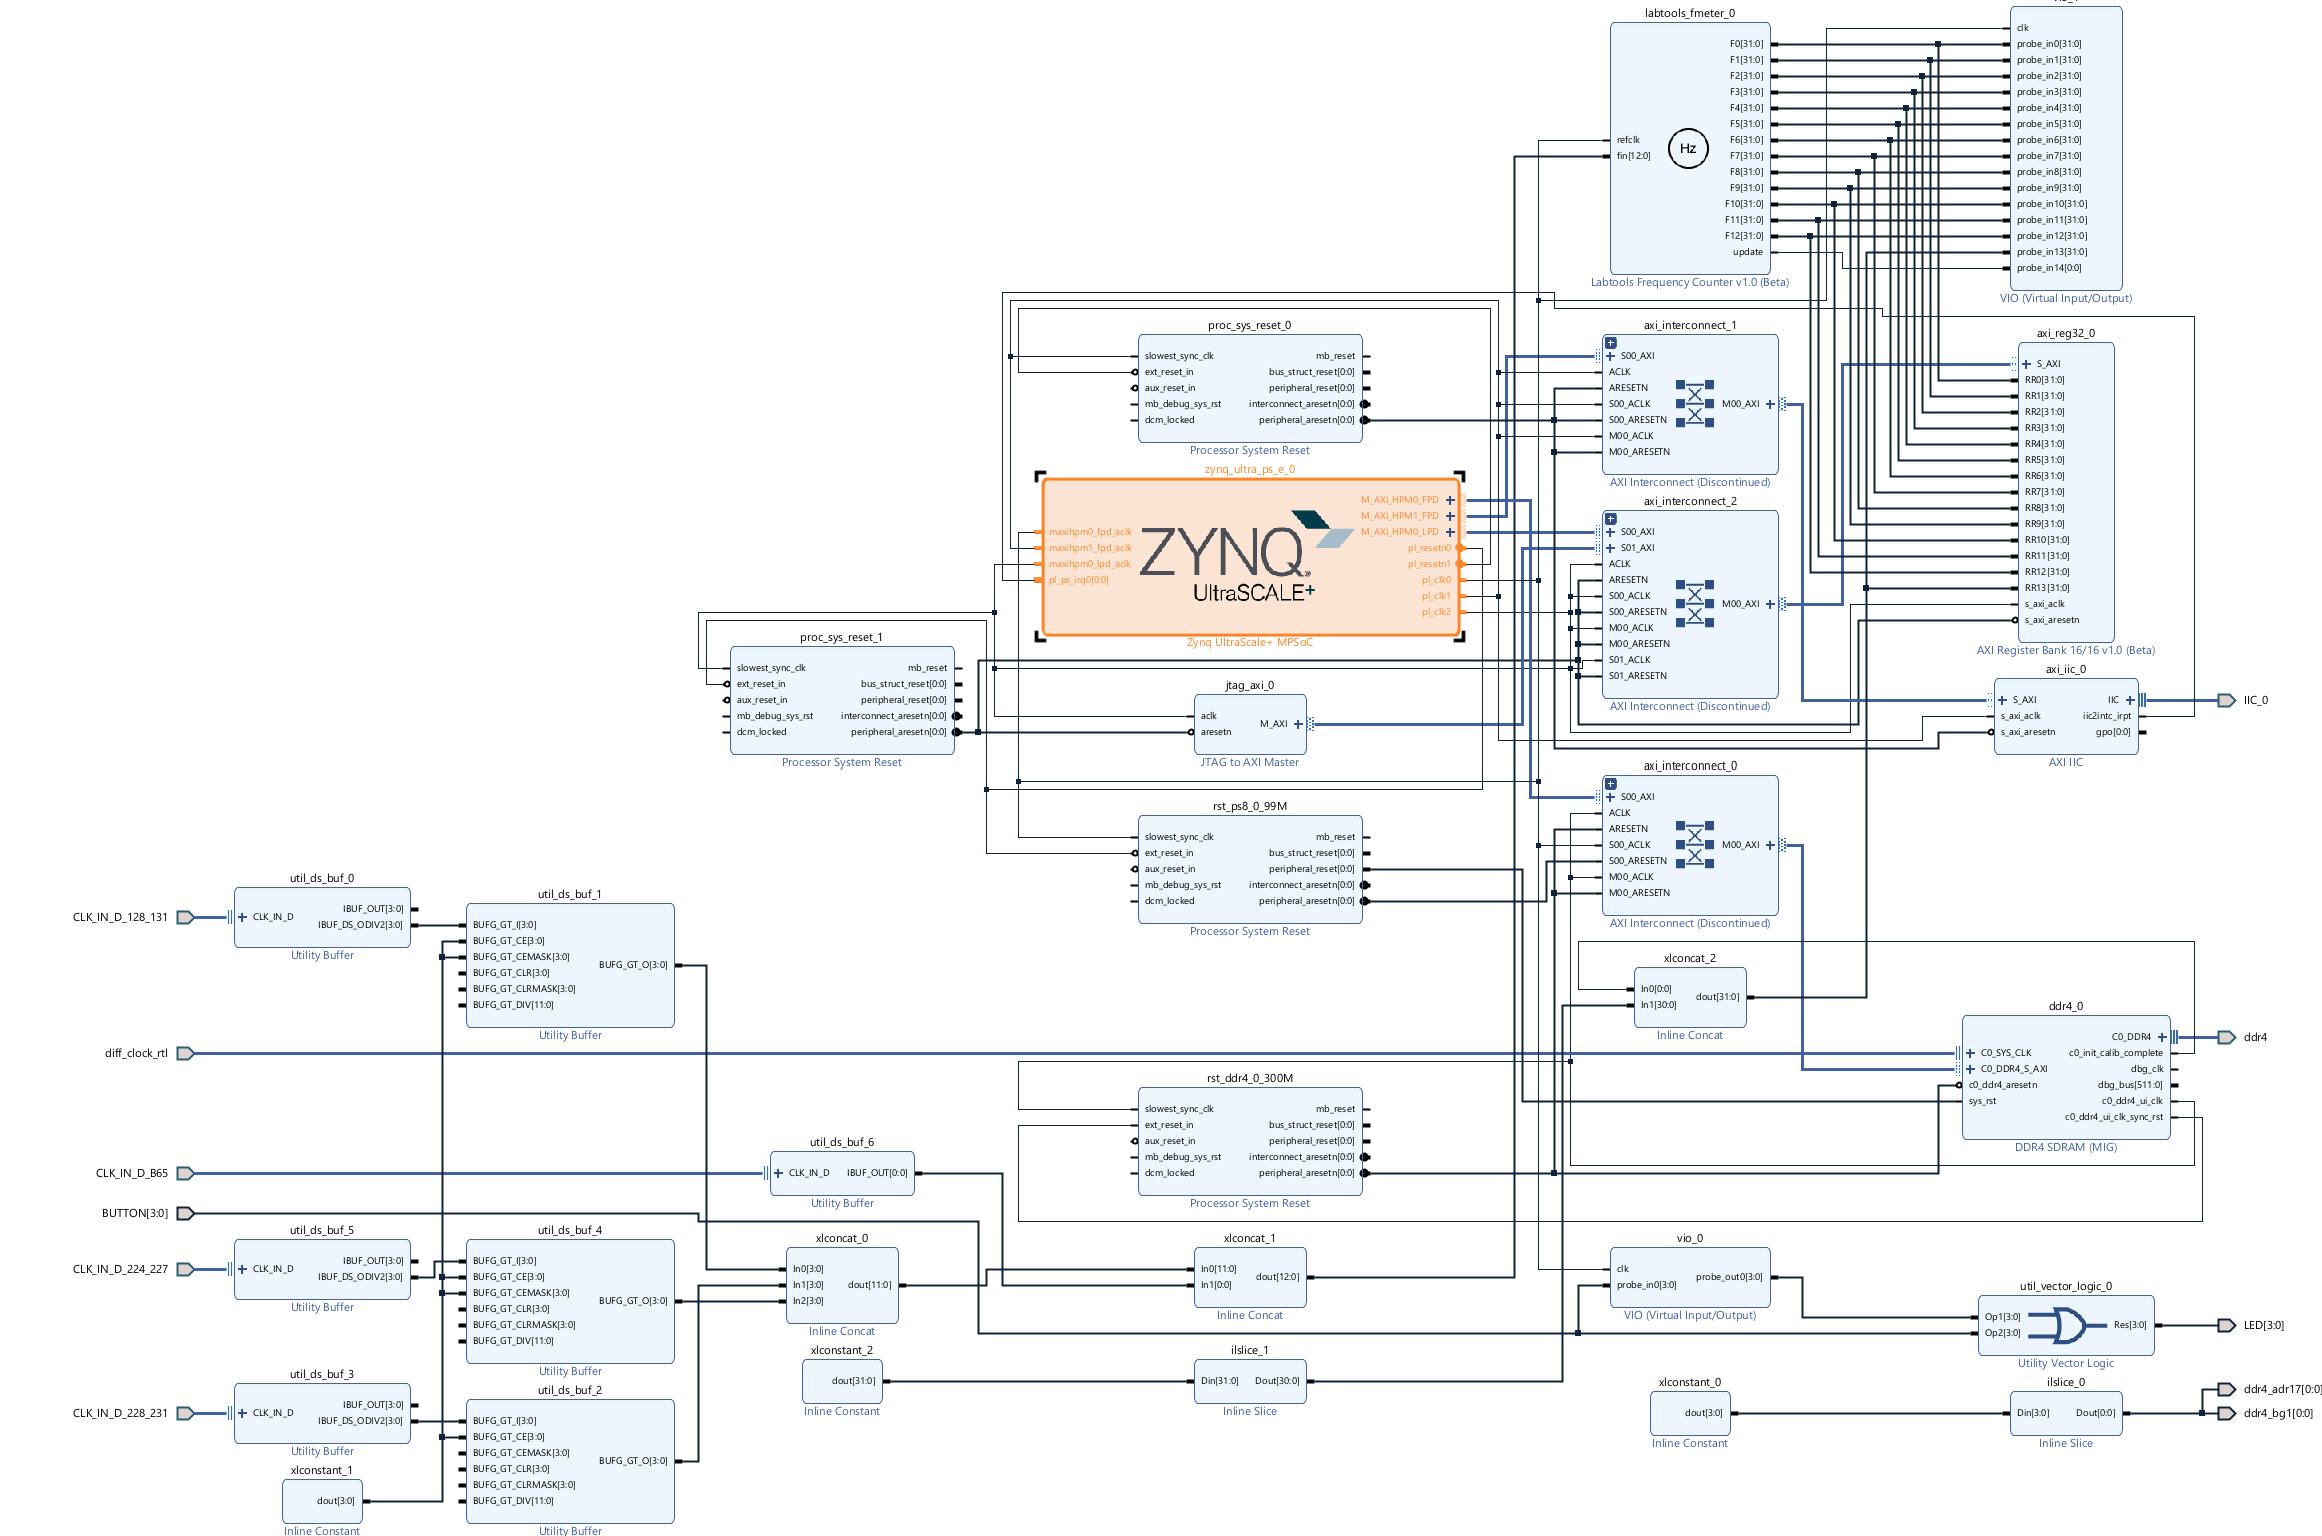
Block Design
PS Interfaces
Activated interfaces:
| Type | Note |
|---|---|
| DDR | |
| QSPI | MIO |
| SD1 | MIO |
| I2C0 | MIO |
| I2C1 | MIO |
| UART0 | MIO |
| GPIO0..2 | MIO |
| SWDT0..1 | |
| TTC0..3 | |
| GEM2 | MIO |
| GEM3 | MIO |
| PCIe | MIO/GTP |
| CAN0 | MIO |
PS Interfaces
Constrains
Basic module constrains
_i_bitgen_common.xdc
set_property BITSTREAM.GENERAL.COMPRESS TRUE [current_design]
set_property BITSTREAM.CONFIG.UNUSEDPIN PULLUP [current_design]
Design specific constrain
_i_io.xdc
# AB34 MGT_128_CLK_P
# AB35 MGT_128_CLK_N
# W32 MGT_129_CLK_P
# W33 MGT_129_CLK_N
# R32 MGT_130_CLK_P
# R33 MGT_130_CLK_N
# L32 MGT_131_CLK_P
# L33 MGT_131_CLK_N
set_property PACKAGE_PIN AB34 [get_ports {CLK_IN_D_128_131_clk_p[0]}]
set_property PACKAGE_PIN W32 [get_ports {CLK_IN_D_128_131_clk_p[1]}]
set_property PACKAGE_PIN R32 [get_ports {CLK_IN_D_128_131_clk_p[2]}]
set_property PACKAGE_PIN L32 [get_ports {CLK_IN_D_128_131_clk_p[3]}]

# AB11 MGT_228_CLK_N
# AB12 MGT_228_CLK_P
# Y11 MGT_229_CLK_N
# Y12 MGT_229_CLK_P
# V11 MGT_230_CLK_N
# V12 MGT_230_CLK_P
# T11 MGT_231_CLK_N
# T12 MGT_231_CLK_P
set_property PACKAGE_PIN AB12 [get_ports {CLK_IN_D_228_231_clk_p[0]}]
set_property PACKAGE_PIN Y12 [get_ports {CLK_IN_D_228_231_clk_p[1]}]
set_property PACKAGE_PIN V12 [get_ports {CLK_IN_D_228_231_clk_p[2]}]
set_property PACKAGE_PIN T12 [get_ports {CLK_IN_D_228_231_clk_p[3]}]

# AK11 MGT_224_CLK_N
# AK12 MGT_224_CLK_P
# AH11 MGT_225_CLK_N
# AH12 MGT_225_CLK_P
# AF11 MGT_226_CLK_N
# AF12 MGT_226_CLK_P
# AD11 MGT_227_CLK_N
# AD12 MGT_227_CLK_P
set_property PACKAGE_PIN AK12 [get_ports {CLK_IN_D_224_227_clk_p[0]}]
set_property PACKAGE_PIN AH12 [get_ports {CLK_IN_D_224_227_clk_p[1]}]
set_property PACKAGE_PIN AF12 [get_ports {CLK_IN_D_224_227_clk_p[2]}]
set_property PACKAGE_PIN AD12 [get_ports {CLK_IN_D_224_227_clk_p[3]}]

# B65 CLK
set_property PACKAGE_PIN AR24 [get_ports {CLK_IN_D_B65_clk_p[0]}]
set_property IOSTANDARD LVDS [get_ports {CLK_IN_D_B65_clk_p[0]}]


#get_property -dict { IOSTANDARD LVCMOS33 PACKAGE_PIN D3 } [get_ports {+3.3V_ETH_PHY_EN}] #removed on REV02 --> use unused pullup for rev01
#set_property -dict { IOSTANDARD LVCMOS33 PACKAGE_PIN C1 } [get_ports {+3.3V_M2_KeyE_EN}] #removed on REV02 --> use unused pullup for rev01
#set_property -dict { IOSTANDARD LVCMOS33 PACKAGE_PIN G10 } [get_ports {ssd1_perstn[0]}]
set_property -dict { IOSTANDARD LVCMOS33 PACKAGE_PIN B6 } [get_ports {LED[0]}]
set_property -dict { IOSTANDARD LVCMOS33 PACKAGE_PIN B5 } [get_ports {LED[1]}]
set_property -dict { IOSTANDARD LVCMOS33 PACKAGE_PIN A5 } [get_ports {LED[2]}]
set_property -dict { IOSTANDARD LVCMOS33 PACKAGE_PIN A4 } [get_ports {LED[3]}]
#set_property -dict { IOSTANDARD LVCMOS33 PACKAGE_PIN G13 } [get_ports {M2M_SLEEP[0]}]
#set_property -dict { IOSTANDARD LVCMOS33 PACKAGE_PIN F13 PULLUP TRUE } [get_ports {ssd1_wake[0]}] #removed on REV02 --> use unused pullup for rev01
#
# B10 FF10_MPRS
# C10 FF01_MPRS
# C11 FF00_MPRS
# D11 FF31_MPRS
# D12 FF30_MPRS
# E10 FF20_MPRS
# E11 FF11_MPRS
# E12 FF21_MPRS
# J12 FFA_SDA
# J14 FFA_SCL
# K10 FFD_MPRS
# K11 FFD_MSEL
# K12 FFC_MPRS
# K14 FFA_INTL
# L10 FFD_INTL
# L12 FFC_MSEL
# L13 FFA_MPRS
# L14 FFA_MSEL
# M10 FFD_SDA
# M11 FFB_SDA
# M13 FFB_SCL
# N10 FFD_SCL
# N11 FF_AB_RSTL
# N12 FF_CD_RSTL
# N13 FFB_MSEL
# N14 FFB_INTL
# P12 FFC_INTL
# P13 FFC_SCL
# P14 FFB_MPRS
# R14 FFC_SDA
#
# E3 PEX_FATAL_ERRORn REV02 only
# E4 PEX_GPIO3 REV02 only
# E5 PEX_LANE_GOOD2n REV02 only
# F4 PEX_LANE_GOOD1n REV02 only
# F5 PEX_LANE_GOOD0n REV02 only
#
# F6 DSPLL1_RST_N
# F7 DSPLL0_RST_N
#
# G11 W_DISABLE1n REV01 other name
# G12 W_DISABLE2n REV01 other name
# G13 M2M_SLEEP REV02 only
#
# F10 SSD1_CLKRQ REV01 only
# F13 SSD1_WAKE REV01 only
# G10 SSD1_PERSTn REV01 only
# G13 M2M_SLEEP REV01 other nameSSD1_SLEEP


set_property -dict { IOSTANDARD LVCMOS18 PACKAGE_PIN AK23 } [get_ports {BUTTON[0]}]
set_property -dict { IOSTANDARD LVCMOS18 PACKAGE_PIN AL23 } [get_ports {BUTTON[1]}]
set_property -dict { IOSTANDARD LVCMOS18 PACKAGE_PIN AJ24 } [get_ports {BUTTON[2]}]
set_property -dict { IOSTANDARD LVCMOS18 PACKAGE_PIN AK24 } [get_ports {BUTTON[3]}]

set_property -dict { IOSTANDARD DIFF_SSTL12_DCI PACKAGE_PIN G26 } [get_ports {diff_clock_rtl_clk_p}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN N24 } [get_ports {ddr4_act_n}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN J27 } [get_ports {ddr4_adr[0]}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN J24 } [get_ports {ddr4_adr[1]}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN F27 } [get_ports {ddr4_adr[2]}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN E26 } [get_ports {ddr4_adr[3]}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN M25 } [get_ports {ddr4_adr[4]}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN D26 } [get_ports {ddr4_adr[5]}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN K27 } [get_ports {ddr4_adr[6]}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN E27 } [get_ports {ddr4_adr[7]}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN K26 } [get_ports {ddr4_adr[8]}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN H26 } [get_ports {ddr4_adr[9]}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN L24 } [get_ports {ddr4_adr[10]}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN F28 } [get_ports {ddr4_adr[11]}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN J23 } [get_ports {ddr4_adr[12]}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN J26 } [get_ports {ddr4_adr[13]}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN L23 } [get_ports {ddr4_adr[14]}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN K24 } [get_ports {ddr4_adr[15]}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN H23 } [get_ports {ddr4_adr[16]}]

## /* dummy for ddr4-ram */
set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN G25 } [get_ports {ddr4_adr17[0]}]


#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN N26 } [get_ports {ddr4_ba[0]}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN G23 } [get_ports {ddr4_ba[1]}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN M23 } [get_ports {ddr4_bg[0]}]
#set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN P23 } [get_ports {ddr4_bg[1]}]

## /* dummy for ddr4-ram */
set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN P23 } [get_ports {ddr4_bg1[0]}]

#moved to board files# set_property -dict { IOSTANDARD DIFF_SSTL12_DCI PACKAGE_PIN F25 } [get_ports {ddr4_ck_t[0]}]
#moved to board files# set_property -dict { IOSTANDARD DIFF_SSTL12_DCI PACKAGE_PIN E25 } [get_ports {ddr4_ck_c[0]}]

#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN L25 } [get_ports {ddr4_cke[0]}]
#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN N23 } [get_ports {ddr4_cs_n[0]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN P18 } [get_ports {ddr4_dm_n[0]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN K19 } [get_ports {ddr4_dm_n[1]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN D19 } [get_ports {ddr4_dm_n[2]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN G22 } [get_ports {ddr4_dm_n[3]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN K29 } [get_ports {ddr4_dm_n[4]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN E29 } [get_ports {ddr4_dm_n[5]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN C36 } [get_ports {ddr4_dm_n[6]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN E32 } [get_ports {ddr4_dm_n[7]}]

#moved to board files# set_property -dict { IOSTANDARD DIFF_POD12_DCI PACKAGE_PIN N19 } [get_ports {ddr4_dqs_c[0]}]
#moved to board files# set_property -dict { IOSTANDARD DIFF_POD12_DCI PACKAGE_PIN J22 } [get_ports {ddr4_dqs_c[1]}]
#moved to board files# set_property -dict { IOSTANDARD DIFF_POD12_DCI PACKAGE_PIN B21 } [get_ports {ddr4_dqs_c[2]}]
#moved to board files# set_property -dict { IOSTANDARD DIFF_POD12_DCI PACKAGE_PIN E20 } [get_ports {ddr4_dqs_c[3]}]
#moved to board files# set_property -dict { IOSTANDARD DIFF_POD12_DCI PACKAGE_PIN F30 } [get_ports {ddr4_dqs_c[4]}]
#moved to board files# set_property -dict { IOSTANDARD DIFF_POD12_DCI PACKAGE_PIN A32 } [get_ports {ddr4_dqs_c[5]}]
#moved to board files# set_property -dict { IOSTANDARD DIFF_POD12_DCI PACKAGE_PIN A40 } [get_ports {ddr4_dqs_c[6]}]
#moved to board files# set_property -dict { IOSTANDARD DIFF_POD12_DCI PACKAGE_PIN C34 } [get_ports {ddr4_dqs_c[7]}]
#moved to board files# set_property -dict { IOSTANDARD DIFF_POD12_DCI PACKAGE_PIN N20 } [get_ports {ddr4_dqs_t[0]}]
#moved to board files# set_property -dict { IOSTANDARD DIFF_POD12_DCI PACKAGE_PIN K22 } [get_ports {ddr4_dqs_t[1]}]
#moved to board files# set_property -dict { IOSTANDARD DIFF_POD12_DCI PACKAGE_PIN C21 } [get_ports {ddr4_dqs_t[2]}]
#moved to board files# set_property -dict { IOSTANDARD DIFF_POD12_DCI PACKAGE_PIN F20 } [get_ports {ddr4_dqs_t[3]}]
#moved to board files# set_property -dict { IOSTANDARD DIFF_POD12_DCI PACKAGE_PIN G30 } [get_ports {ddr4_dqs_t[4]}]
#moved to board files# set_property -dict { IOSTANDARD DIFF_POD12_DCI PACKAGE_PIN B31 } [get_ports {ddr4_dqs_t[5]}]
#moved to board files# set_property -dict { IOSTANDARD DIFF_POD12_DCI PACKAGE_PIN A39 } [get_ports {ddr4_dqs_t[6]}]
#moved to board files# set_property -dict { IOSTANDARD DIFF_POD12_DCI PACKAGE_PIN D34 } [get_ports {ddr4_dqs_t[7]}]

#moved to board files# set_property -dict { IOSTANDARD SSTL12_DCI PACKAGE_PIN H24 } [get_ports {ddr4_odt[0]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN N25 } [get_ports {ddr4_reset_n}]

#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN N21 } [get_ports {ddr4_dq[0]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN M18 } [get_ports {ddr4_dq[1]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN M21 } [get_ports {ddr4_dq[2]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN M20 } [get_ports {ddr4_dq[3]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN P21 } [get_ports {ddr4_dq[4]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN L18 } [get_ports {ddr4_dq[5]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN M22 } [get_ports {ddr4_dq[6]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN L19 } [get_ports {ddr4_dq[7]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN H19 } [get_ports {ddr4_dq[8]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN L20 } [get_ports {ddr4_dq[9]}]

#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN H20 } [get_ports {ddr4_dq[10]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN K21 } [get_ports {ddr4_dq[11]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN G20 } [get_ports {ddr4_dq[12]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN K20 } [get_ports {ddr4_dq[13]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN H21 } [get_ports {ddr4_dq[14]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN J21 } [get_ports {ddr4_dq[15]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN B22 } [get_ports {ddr4_dq[16]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN C20 } [get_ports {ddr4_dq[17]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN A22 } [get_ports {ddr4_dq[18]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN A19 } [get_ports {ddr4_dq[19]}]

#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN B23 } [get_ports {ddr4_dq[20]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN B20 } [get_ports {ddr4_dq[21]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN A23 } [get_ports {ddr4_dq[22]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN A20 } [get_ports {ddr4_dq[23]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN F22 } [get_ports {ddr4_dq[24]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN E19 } [get_ports {ddr4_dq[25]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN E22 } [get_ports {ddr4_dq[26]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN D21 } [get_ports {ddr4_dq[27]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN F23 } [get_ports {ddr4_dq[28]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN F19 } [get_ports {ddr4_dq[29]}]

#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN D22 } [get_ports {ddr4_dq[30]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN E21 } [get_ports {ddr4_dq[31]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN F31 } [get_ports {ddr4_dq[32]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN J28 } [get_ports {ddr4_dq[33]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN J30 } [get_ports {ddr4_dq[34]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN H28 } [get_ports {ddr4_dq[35]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN F32 } [get_ports {ddr4_dq[36]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN G28 } [get_ports {ddr4_dq[37]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN H30 } [get_ports {ddr4_dq[38]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN F29 } [get_ports {ddr4_dq[39]}]

#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN E31 } [get_ports {ddr4_dq[40]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN C30 } [get_ports {ddr4_dq[41]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN C31 } [get_ports {ddr4_dq[42]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN B30 } [get_ports {ddr4_dq[43]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN D31 } [get_ports {ddr4_dq[44]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN C29 } [get_ports {ddr4_dq[45]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN A30 } [get_ports {ddr4_dq[46]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN A29 } [get_ports {ddr4_dq[47]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN C42 } [get_ports {ddr4_dq[48]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN B36 } [get_ports {ddr4_dq[49]}]

#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN B40 } [get_ports {ddr4_dq[50]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN B37 } [get_ports {ddr4_dq[51]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN B42 } [get_ports {ddr4_dq[52]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN A37 } [get_ports {ddr4_dq[53]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN B41 } [get_ports {ddr4_dq[54]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN A38 } [get_ports {ddr4_dq[55]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN B35 } [get_ports {ddr4_dq[56]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN B32 } [get_ports {ddr4_dq[57]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN A33 } [get_ports {ddr4_dq[58]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN D33 } [get_ports {ddr4_dq[59]}]

#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN A35 } [get_ports {ddr4_dq[60]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN A34 } [get_ports {ddr4_dq[61]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN C33 } [get_ports {ddr4_dq[62]}]
#moved to board files# set_property -dict { IOSTANDARD POD12_DCI PACKAGE_PIN B33 } [get_ports {ddr4_dq[63]}]

set_property -dict { IOSTANDARD LVCMOS33 PACKAGE_PIN J9 } [get_ports {IIC_0_scl_io}]
set_property -dict { IOSTANDARD LVCMOS33 PACKAGE_PIN H9 } [get_ports {IIC_0_sda_io}]


#create_clock -name c0_sys_clk -period 4.998 [get_ports diff_clock_rtl_clk_p]
tig.xdc
# ignore timing for calibration done signal to vio core
set_property DONT_TOUCH true [get_cells -hier *vio_1]
set_false_path -through  [get_pins -hier *vio_1/probe_in13[0]]
set_false_path  -to [get_pins {*/axi_reg32_0/U0/axi_reg32_v1_0_S_AXI_inst/axi_rdata_reg[0]/D}]
Software Design - Vitis
For Vitis project creation, follow instructions from:
Application
Template location: "<project folder>\sw_lib\sw_apps\"zynqmp_fsbl
TE modified 2024.2 FSBL
General:
- Modified Files: xfsbl_main.c, xfsbl_hooks.h/.c, xfsbl_board.h/.c (search for 'TE Mod' on source code)
- Add Files: te_xfsbl_hooks.h/.c (for hooks and board)
- General Changes:
- Display FSBL Banner and Device Name
Module Specific:
- Add Files: all TE Files start with te_*
- Si5395 DSPLL0 (U64) configuration
- Si5395 DSPLL1 (U65) configuration
- PCIe and eth reset
zynqmp_pmufw
Xilinx default PMU firmware.
----------------------------------------------------------
General Example:
hello_trenz
Hello Trenz is a Xilinx Hello World example as endless loop instead of one console output.
u-boot
U-Boot.elf is generated with PetaLinux. Vitis is used to generate Boot.bin.
Software Design - PetaLinux
For PetaLinux installation and project creation, follow instructions from:
Config
Start with petalinux-config or petalinux-config --get-hw-description
Changes:
- add new flash partition for bootscr and sizing
- CONFIG_SUBSYSTEM_FLASH_PSU_QSPI_0_PART0_NAME="qspi-boot"
- CONFIG_SUBSYSTEM_FLASH_PSU_QSPI_0_PART0_SIZE=0xA00000
- CONFIG_SUBSYSTEM_FLASH_PSU_QSPI_0_PART1_NAME="qspi-image"
- CONFIG_SUBSYSTEM_FLASH_PSU_QSPI_0_PART1_SIZE=0x4000000
- CONFIG_SUBSYSTEM_FLASH_PSU_QSPI_0_PART2_NAME="qspi-bootenv"
- CONFIG_SUBSYSTEM_FLASH_PSU_QSPI_0_PART2_SIZE=0x40000
- CONFIG_SUBSYSTEM_FLASH_PSU_QSPI_0_PART3_NAME="qspi-bootscr"
- CONFIG_SUBSYSTEM_FLASH_PSU_QSPI_0_PART3_SIZE=0x80000
- CONFIG_SUBSYSTEM_FLASH_PSU_QSPI_0_PART4_NAME="qspi-spare"
- CONFIG_SUBSYSTEM_FLASH_PSU_QSPI_0_PART4_SIZE=0x3540000
- CONFIG_SUBSYSTEM_UBOOT_QSPI_FIT_IMAGE_OFFSET=0xA00000
- CONFIG_SUBSYSTEM_UBOOT_QSPI_FIT_IMAGE_SIZE=0x4000000
- Identification
- CONFIG_SUBSYSTEM_HOSTNAME="Trenz"
- CONFIG_SUBSYSTEM_PRODUCT="TEB0912"
U-Boot
Start with petalinux-config -c u-boot
Changes:
- MAC from eeprom together with uboot and device tree settings:
- CONFIG_ENV_OVERWRITE=y
- CONFIG_NVMEM=y
- CONFIG_DM_RTC=y (needed for nvmem driver because of bug in uboot)
- Boot Modes:
- CONFIG_QSPI_BOOT=y
- CONFIG_SD_BOOT=y
- CONFIG_ENV_IS_IN_FAT is not set
- CONFIG_ENV_IS_IN_NAND is not set
- CONFIG_ENV_IS_IN_SPI_FLASH is not set
- CONFIG_BOOT_SCRIPT_OFFSET=0x4A40000
- Add AXI I2C driver:
- CONFIG_SYS_I2C_XILINX_XIIC=y
- Identification
- CONFIG_IDENT_STRING=" TEB0912"
Change platform-top.h:
Device Tree
/include/ "system-conf.dtsi"
/ {
/*------------------ PS-PL CLK --------------------*/
  fclk0: fclk0 {
    status = "okay";
    compatible = "xlnx,fclk";
    clocks = <&zynqmp_clk PL0_REF>;
    //clocks = <&zynqmp_clk 71>;
    clock-names = "pl_clk0";
  };

  fclk1: fclk1 {
    status = "okay";
    compatible = "xlnx,fclk";
    clocks = <&zynqmp_clk PL1_REF>;
    clock-names = "pl_clk1";
  };

  fclk2: fclk2 {
    status = "okay";
    compatible = "xlnx,fclk";
    clocks = <&zynqmp_clk PL2_REF>;
    clock-names = "pl_clk2";
  };
};


/*------------------ gtr --------------------*/

//https://xilinx-wiki.atlassian.net/wiki/spaces/A/pages/18841716/Zynq+Ultrascale+MPSOC+Linux+SIOU+driver

/ {
  refclk0:psgtr_pcie_clock {
          compatible = "fixed-clock";
          #clock-cells = <0x00>;
          clock-frequency = <100000000>;
  };
};

&psgtr {
  clocks = <&refclk0>;
  //clocks = <&refclk0 &refclk2 &refclk3>;
  /* ref clk instances used per lane */
  clock-names = "ref0";
};

/*------------------------- ETH PHY -----------------------*/


&gem2 {
    status = "okay";
    phy-handle = <ðernet_phy2>;

    nvmem-cells = <ð2_addr>;
    nvmem-cell-names = "mac-address";

    //required otherwise petalinux gives a static address here
    /delete-property/ local-mac-address;

    mdio {

      ethernet_phy1: ethernet-phy@0 {

          //compatible = "marvell,88e1510";
          reg = <0>;
          #address-cells = <0x1>;
          #size-cells = <0x1>;
      };

      ethernet_phy2: ethernet-phy@1 {

          //compatible = "marvell,88e1510";
          reg = <1>;
          #address-cells = <0x1>;
          #size-cells = <0x1>;
      };

    };
};


&gem3 {
    status = "okay";
    phy-mode = "rgmii-id";
    phy-handle = <ðernet_phy1>;

    nvmem-cells = <ð1_addr>;
    nvmem-cell-names = "mac-address";

    //required otherwise petalinux gives a static address here
    /delete-property/ local-mac-address;

};


/*-------------------- SD1 SD3.0 ----------------*/

&sdhci1 {
    pinctrl-names = "default";
    pinctrl-0 = <&pinctrl_sdhci1_default>;
    no-1-8-v;
    disable-wp;
};

&pinctrl0 {
    status = "okay";
    pinctrl_sdhci1_default: sdhci1-default {
        mux {
            groups = "sdio1_0_grp";
            function = "sdio1";
        };

        conf {
            groups = "sdio1_0_grp";
            slew-rate = <1>;
            io-standard = <1>;
            bias-disable;
        };
/*
        mux-cd {
            groups = "sdio1_cd_0_grp";
            function = "sdio1_cd";
        };

        conf-cd {
            groups = "sdio1_cd_0_grp";
            bias-high-impedance;
            bias-pull-up;
            slew-rate = <1>;
            io-standard = <1>;
        };

        mux-wp {
            groups = "sdio1_wp_0_grp";
            function = "sdio1_wp";
        };

        conf-wp {
            groups = "sdio1_wp_0_grp";
            bias-high-impedance;
            bias-pull-up;
            slew-rate = <1>;
            io-standard = <1>;
        };
*/

    };
};
/*-------------------- QSPI ---------------------*/
&qspi {
    num-cs = <2>;

    flash@0 {
        compatible = "jedec,spi-nor";
        reg = <0>, <1>;
        parallel-memories = /bits/ 64 <0x10000000 0x10000000>;
        /* 0x10000000 =  256MB dual as maximum;
           this is a proprietary property from u-boot/linux-xlnx. it is used in u-boot and does work if it is larger than the connected qspi, even though the displayed size if wrong
           we implemented a linux patch that uses the size which is read back from the qspi itself
        */
        spi-rx-bus-width = <4>;
        spi-tx-bus-width = <4>;
        spi-max-frequency = <108000000>; // max. frequency also depends on the QSPI chip
                                         // here 108MHz for N25Q512A (Fast Read Quad IO STR, 8 Dummy Cycles, quad SPI protocol)

        #address-cells = <1>;
        #size-cells = <1>;
    };
};

/*-------------------- RTC ----------------------*/
/* TEB0912 is without rty crystal, external RTC isl12022 is used */
&rtc {
    status = "disabled";
};


/*-------------------- I2C Bus on PL ----------------------*/
/* for CPLD I2C controller */
&axi_iic_0 {
        iexp@20 {// GPIO in CPLD
            #gpio-cells = <2>;
            //compatible = "ti,pcf8574";
            reg = <0x20>;
            gpio-controller;

        };
};

/*----------------- I2C Bus on PS MIO 34,35 ---------------*/
/* on MIO */
&i2c0 {
    eeprom51: eeprom@51 {
        compatible = "microchip,24aa025", "atmel,24c02";
        reg = <0x51>;

        #address-cells = <1>;
        #size-cells = <1>;
        eth2_addr: eth-mac-addr@FA {
          reg = <0xFA 0x06>;
        };
    };

    eeprom52: eeprom@52 {
        compatible = "microchip,24aa025", "atmel,24c02";
        reg = <0x52>;

        #address-cells = <1>;
        #size-cells = <1>;
        eth1_addr: eth-mac-addr@FA {
          reg = <0xFA 0x06>;

        };
    };

    eeprom53: eeprom@53 {
        compatible = "microchip,24aa025", "atmel,24c02";
        reg = <0x53>;
    };

    eeprom56: eeprom@56 {
        compatible = "microchip,24lc128", "atmel,24c128";
        reg = <0x56>;
    };

    rtc@6F {        // Real Time Clock
        compatible = "isl12022";
        reg = <0x6F>;
    };

};


/*----------------- I2C Bus on PS MIO 28,29 ---------------*/
&i2c1 {
    i2cswitch@75 { // u35
        compatible = "nxp,pca9544";
        #address-cells = <1>;
        #size-cells = <0>;
        reg = <0x70>;
        i2c-mux-idle-disconnect;
        i2c@0 { // DSPLL0
            reg = <0>;
        };
        i2c@1 { // DSPLL1
            reg = <1>;
        };
        i2c@2 { // J34
            reg = <2>;
        };
        i2c@3 { // J34
            reg = <3>;
        };
    };
};
Kernel
Start with petalinux-config -c kernel
Changes:
- Only needed to fix JTAG Debug issue:
- # CONFIG_CPU_FREQ is not set
- Support PCIe memory card
- CONFIG_NVME_CORE=y
- CONFIG_BLK_DEV_NVME=y
- # CONFIG_NVME_MULTIPATH is not set
- # CONFIG_NVME_VERBOSE_ERRORS is not set
- # CONFIG_NVME_HWMON is not set
- # CONFIG_NVME_AUTH is not set
- CONFIG_NVME_TARGET=y
- # CONFIG_NVME_TARGET_PASSTHRU is not set
- # CONFIG_NVME_TARGET_LOOP is not set
- # CONFIG_NVME_TARGET_FC is not set
- # CONFIG_NVME_TARGET_TCP is not set
- # CONFIG_NVME_TARGET_AUTH is not set
- CONFIG_SATA_AHCI=y
- CONFIG_SATA_MOBILE_LPM_POLICY=0
Support external RTC:
- CONFIG_RTC_DRV_ISL12022=y
Rootfs
Start with petalinux-config -c rootfs
Changes:
- for web server app:
- CONFIG_busybox-httpd=y
- For additional test tools only:
- CONFIG_i2c-tools=y
- CONFIG_usbutils=y
- CONFIG_pciutils=y
- Use linux instead of busybox utiles
- CONFIG_util-linux=y
- For auto login:
- CONFIG_imagefeature-serial-autologin-root=y
FSBL patch (alternative for vitis fsbl trenz patch)
See "<project folder>\os\petalinux\project-spec\meta-user\recipes-bsp\embeddedsw"
te_* files are identical to files in "<project folder>\sw_lib\sw_apps\zynqmp_fsbl\src" except for the PLL files (SI5395) which depend on PLL revision. The PLL files may have to be copied again manually into the appropriate petalinux folder "<project folder>\os\petalinux\project-spec\meta-user\recipes-bsp\embeddedsw\fsbl-firmware\git\lib\sw_apps\zynqmp_fsbl\src"
Boot.scr patch
Petalinux template with Trenz debug log prints, see "<project folder>\os\petalinux\project-spec\meta-user\recipes-bsp\u-boot"
QSPI patch
Petalinux patch to read back QSPI size from flash instead device tree parameter, see "<project folder>\os\petalinux\project-spec\meta-user\recipes-kernel\linux\linux-xlnx"
Applications
See "<project folder>\os\petalinux\project-spec\meta-user\recipes-apps\"
startup
Script App to load init.sh from SD Card if available.
webfwu
Webserver application suitable for ZynqMP access. Need busybox-httpd
Additional Software
SI5395 of carrier board DSPLL0 (U64)
File location "<project folder>\misc\PLL\Si5395-*_DSPLL0_*.slabtimeproj"
General documentation how you work with this project will be available on Si5395
SI5395 of carrier board DSPLL1 (U65)
File location "<project folder>\misc\PLL\Si5395-*_DSPLL1_*.slabtimeproj"
General documentation how you work with this project will be available on Si5395
App. A: Change History and Legal Notices
Document Change History
To get content of older revision go to "Change History" of this page and select older document revision number.
| Date | Document Revision | Authors | Description |
|---|---|---|---|
| |||
2025-08-29 | v.13 | John Hartfiel |
|
2023-08-08 | v.12 | Manuela Strücker |
|
| 2021-12-21 | v.10 | Mohsen Chamanbaz |
|
| 2021-07-08 | v.8 | Mohsen Chamanbaz |
|
| 2021-06-28 | v.7 | Mohsen Chamanbaz |
|
2020-06-10 |
| ||
| -- | all | -- |
Document change history.
Legal Notices
Data Privacy
Please also note our data protection declaration at https://www.trenz-electronic.de/en/Data-protection-Privacy
Document Warranty
The material contained in this document is provided “as is” and is subject to being changed at any time without notice. Trenz Electronic does not warrant the accuracy and completeness of the materials in this document. Further, to the maximum extent permitted by applicable law, Trenz Electronic disclaims all warranties, either express or implied, with regard to this document and any information contained herein, including but not limited to the implied warranties of merchantability, fitness for a particular purpose or non infringement of intellectual property. Trenz Electronic shall not be liable for errors or for incidental or consequential damages in connection with the furnishing, use, or performance of this document or of any information contained herein.
Limitation of Liability
In no event will Trenz Electronic, its suppliers, or other third parties mentioned in this document be liable for any damages whatsoever (including, without limitation, those resulting from lost profits, lost data or business interruption) arising out of the use, inability to use, or the results of use of this document, any documents linked to this document, or the materials or information contained at any or all such documents. If your use of the materials or information from this document results in the need for servicing, repair or correction of equipment or data, you assume all costs thereof.
Product Disclaimer
Products (incl. Software and Firmware) are exclusively designed, manufactured, and distributed for industrial applications. They are not intended, authorized, or certified for use in critical safety applications, medical devices, aerospace, nuclear, life-support, traffic-control, military, or other environments where malfunction or failure could result in personal injury, death, or significant property or environmental damage.
Trenz Electronic GmbH (“Manufacturer”) excludes any liability for inappropriate use in such contexts. The Customer bears all responsibility for verifying suitability and compliance with applicable regulations when deploying in any critical-use scenario. The Customer also agrees to indemnify and hold harmless the Manufacturer from any third-party claims or liabilities arising from such use.
Copyright Notice
No part of this manual may be reproduced in any form or by any means (including electronic storage and retrieval or translation into a foreign language) without prior agreement and written consent from Trenz Electronic.
Technology Licenses
The hardware / firmware / software described in this document are furnished under a license and may be used /modified / copied only in accordance with the terms of such license.
Environmental Protection
To confront directly with the responsibility toward the environment, the global community and eventually also oneself. Such a resolution should be integral part not only of everybody's life. Also enterprises shall be conscious of their social responsibility and contribute to the preservation of our common living space. That is why Trenz Electronic invests in the protection of our Environment.
REACH, RoHS and WEEE
REACH
Trenz Electronic is a manufacturer and a distributor of electronic products. It is therefore a so called downstream user in the sense of REACH. The products we supply to you are solely non-chemical products (goods). Moreover and under normal and reasonably foreseeable circumstances of application, the goods supplied to you shall not release any substance. For that, Trenz Electronic is obliged to neither register nor to provide safety data sheet. According to present knowledge and to best of our knowledge, no SVHC (Substances of Very High Concern) on the Candidate List are contained in our products. Furthermore, we will immediately and unsolicited inform our customers in compliance with REACH - Article 33 if any substance present in our goods (above a concentration of 0,1 % weight by weight) will be classified as SVHC by the European Chemicals Agency (ECHA).
RoHS
Trenz Electronic GmbH herewith declares that all its products are developed, manufactured and distributed RoHS compliant.
WEEE
Information for users within the European Union in accordance with Directive 2002/96/EC of the European Parliament and of the Council of 27 January 2003 on waste electrical and electronic equipment (WEEE).
Users of electrical and electronic equipment in private households are required not to dispose of waste electrical and electronic equipment as unsorted municipal waste and to collect such waste electrical and electronic equipment separately. By the 13 August 2005, Member States shall have ensured that systems are set up allowing final holders and distributors to return waste electrical and electronic equipment at least free of charge. Member States shall ensure the availability and accessibility of the necessary collection facilities. Separate collection is the precondition to ensure specific treatment and recycling of waste electrical and electronic equipment and is necessary to achieve the chosen level of protection of human health and the environment in the European Union. Consumers have to actively contribute to the success of such collection and the return of waste electrical and electronic equipment. Presence of hazardous substances in electrical and electronic equipment results in potential effects on the environment and human health. The symbol consisting of the crossed-out wheeled bin indicates separate collection for waste electrical and electronic equipment.
Trenz Electronic is registered under WEEE-Reg.-Nr. DE97922676.
Table of contents
Overview
Content Tools